Robot projects for Arduino and ESP32
These are the projects with a robot chassis or a robot arm in the circuit, or a robot in the name. You will find cars, arms, walkers and a hexapod. Mokxi has 27 of them (2 beginner, 13 intermediate and 12 advanced). Here are 24, from “Robotic hand with flex sensors” to “Wheel-encoder square driver”. Each card says what the project does, the board and parts it needs and its level, and Open in the simulator runs it in your browser in one click, with no account.
How to pick your first one
- Start with “Robotic hand with flex sensors”, a beginner project that needs a servo motor and a flex sensor.
- Most of them are intermediate projects. Pick one a level below what you think you can do, finish it, then move up.
- The parts used most here are the 2WD robot car chassis (14 projects), the L298N motor driver (8) and the servo motor (8). With those on hand, most of this list is open to you.
- Start with a car that only drives forward and stops, then add one sensor at a time. The bugs in a robot are almost always in the last thing added.
24 projects of 27
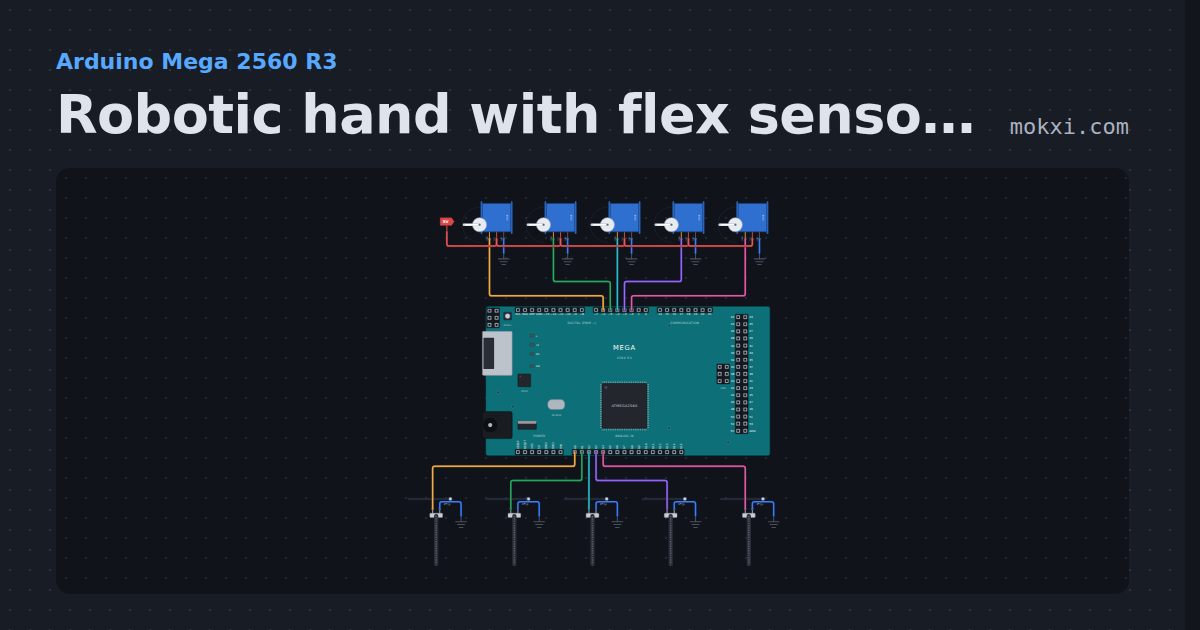
Robotic hand with flex sensors
Robotic hand with flex sensors on an Arduino Mega: five flex sensors on a glove move five servo fingers, and the Serial Monitor names the gesture.
- Board
- Arduino Mega 2560 R3
- Parts
- Servo motor, flex sensor
- Level
- Beginner
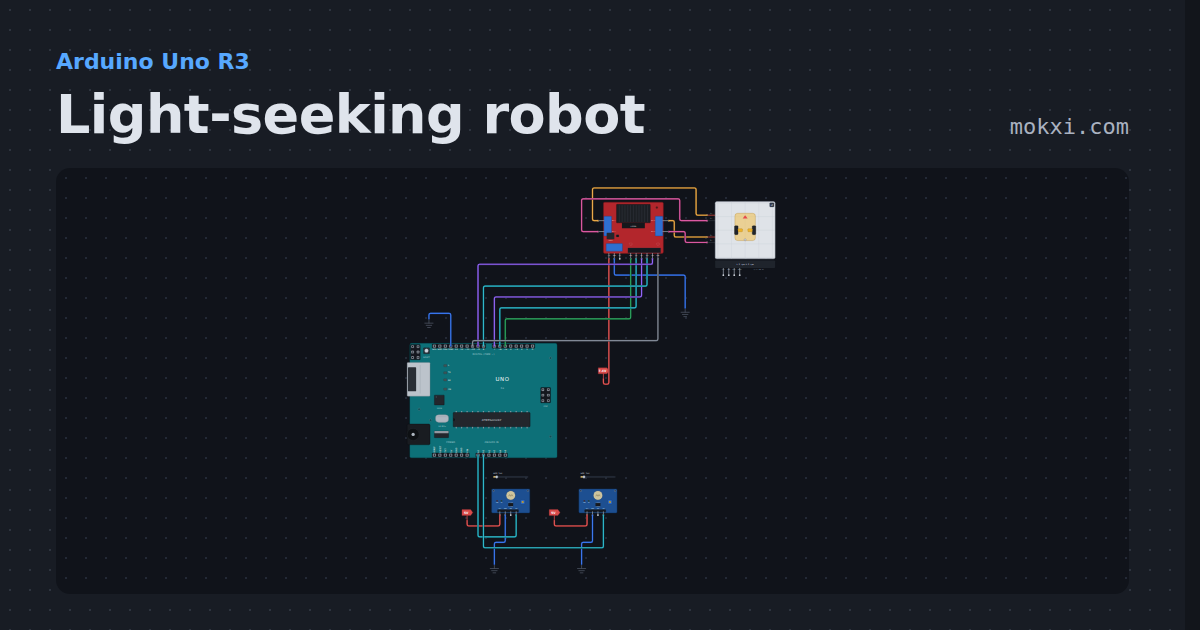
Light-seeking robot
A two-wheel robot with a photoresistor module on each front corner.
- Board
- Arduino Uno R3
- Parts
- L298N motor driver, 2WD robot car chassis, photoresistor module
- Level
- Beginner
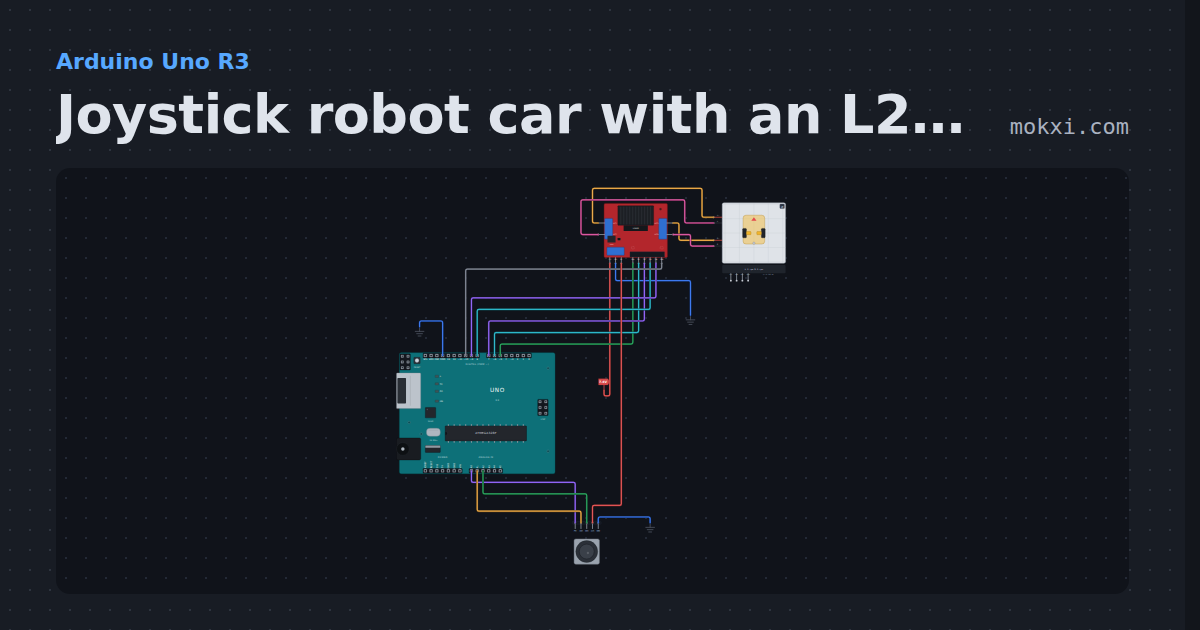
Joystick robot car with an L298N
A thumb stick on A1 and A2 drives a 2WD car on an L298N like a tank: throttle plus steer on one wheel, minus on the other, and a press for slow mode.
- Board
- Arduino Uno R3
- Parts
- L298N motor driver, 2WD robot car chassis, joystick
- Level
- Intermediate
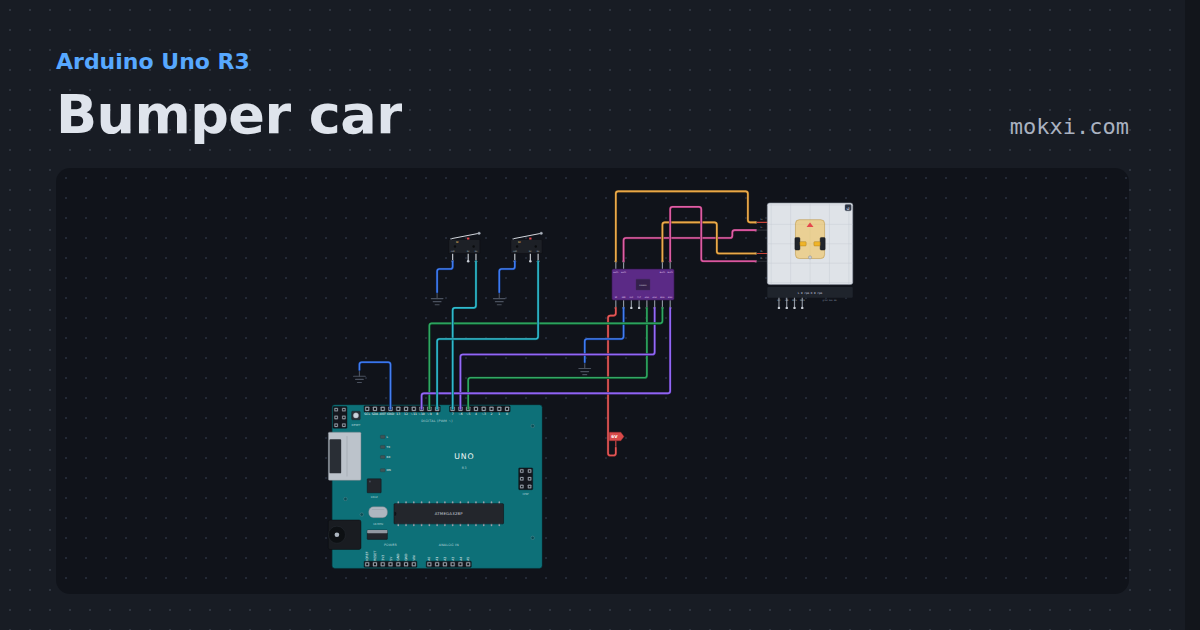
Bumper car
A 2WD robot car on a DRV8833 with two lever microswitches for bumpers. It drives until a bumper is hit, then backs off and turns away from that side.
- Board
- Arduino Uno R3
- Parts
- DRV8833 motor driver, 2WD robot car chassis, limit switch
- Level
- Intermediate
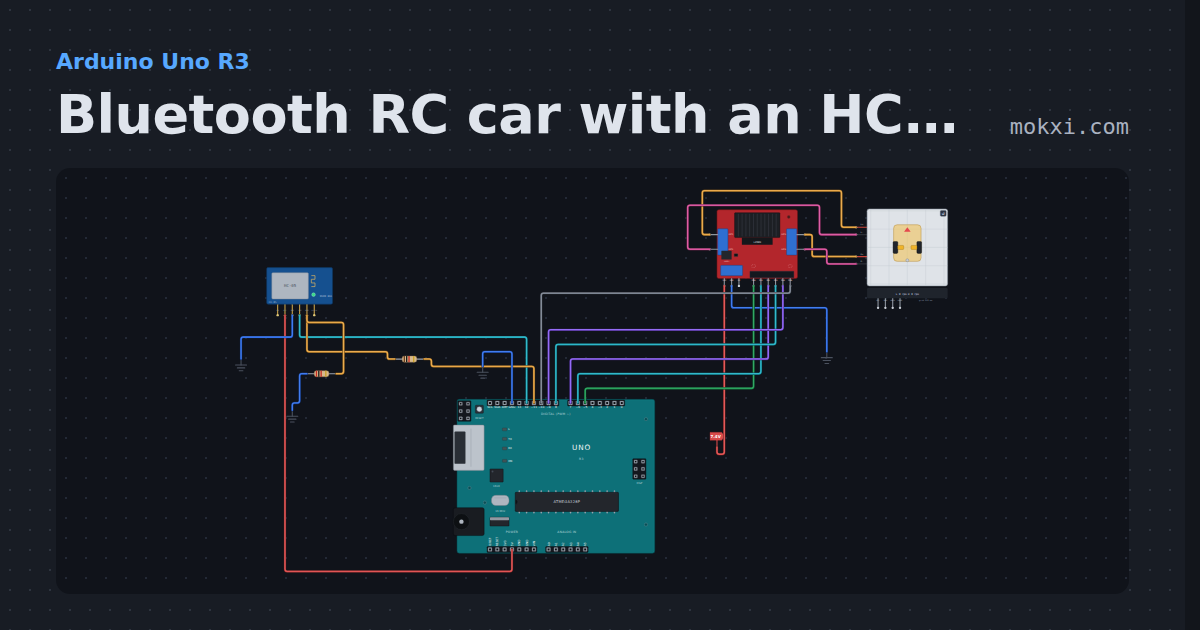
Bluetooth RC car with an HC-05
An HC-05 and a 2WD car on an L298N: type F, B, L, R or S in the module’s box, as a phone app sends them, and the car drives; 0 to 9 set the speed.
- Board
- Arduino Uno R3
- Parts
- L298N motor driver, 2WD robot car chassis, HC-05 Bluetooth module, resistor
- Level
- Intermediate
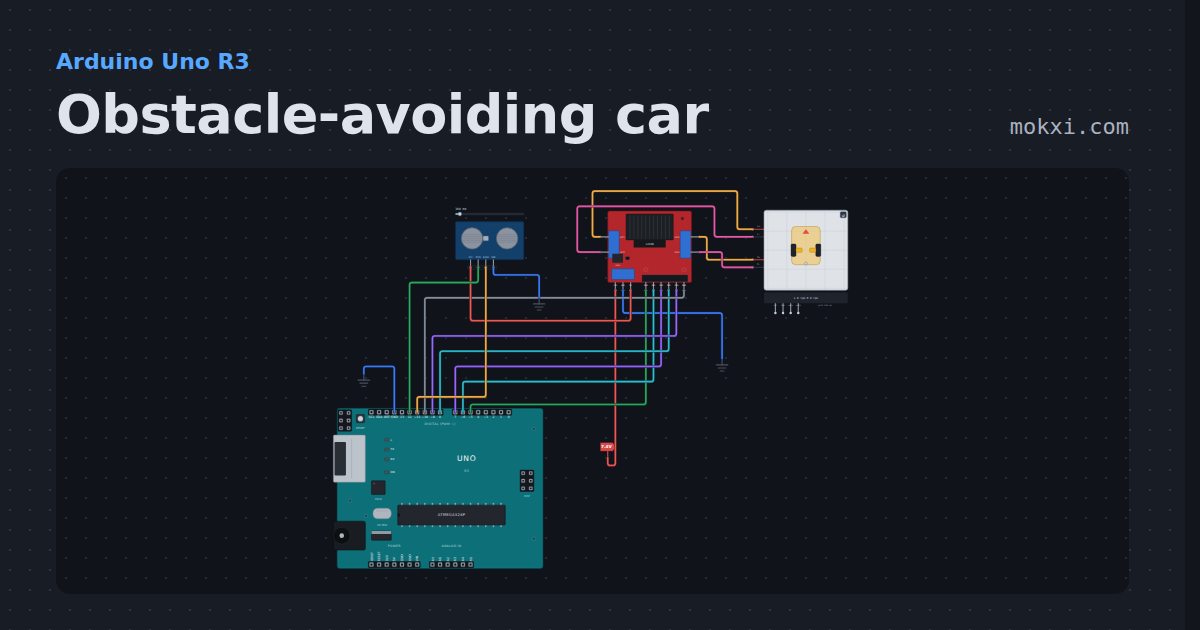
Obstacle-avoiding car
A 2WD robot car on an L298N with an HC-SR04 on the front. It drives ahead, and when something comes within 25 cm it backs up, turns and carries on.
- Board
- Arduino Uno R3
- Parts
- L298N motor driver, 2WD robot car chassis, HC-SR04 ultrasonic sensor
- Level
- Intermediate
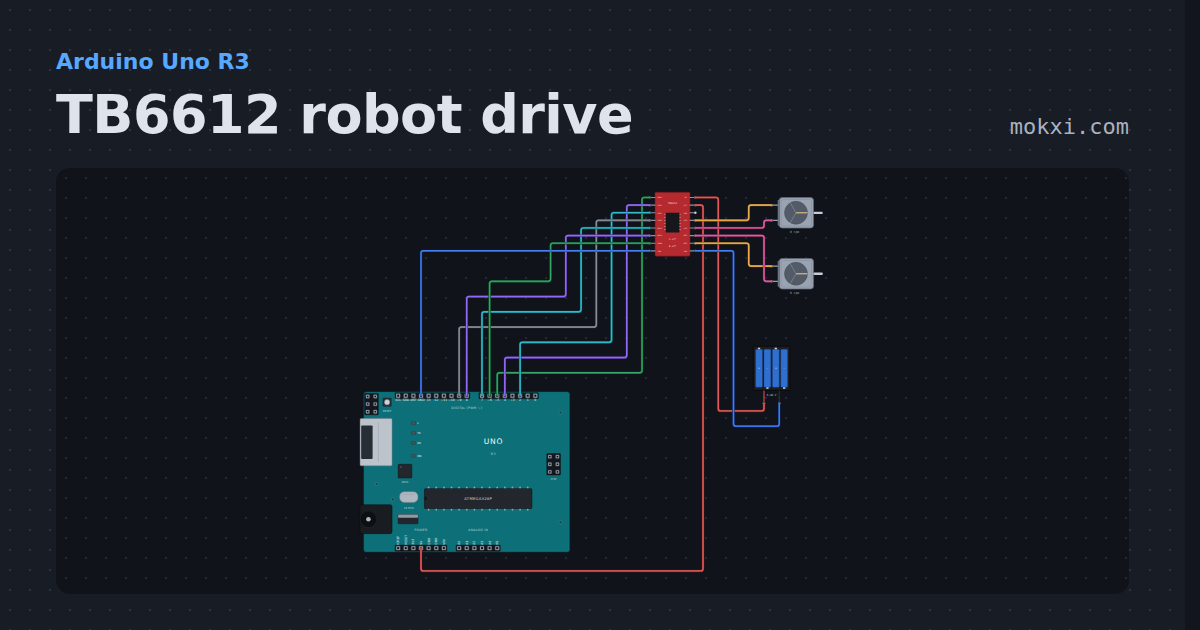
TB6612 robot drive
Two gearbox motors on a TB6612FNG from a four-AA pack, with the SparkFun library: forward, half speed, a spin, reverse, a brake and standby.
- Board
- Arduino Uno R3
- Parts
- TB6612FNG motor driver, DC motor, battery: AA
- Level
- Intermediate
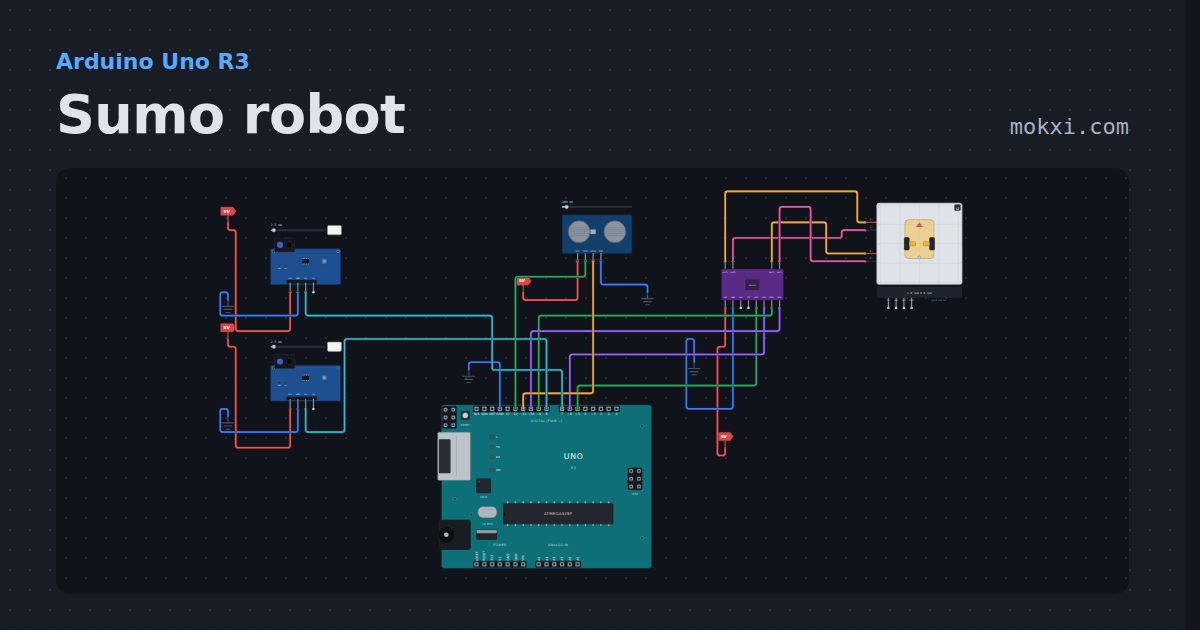
Sumo robot
A mini-sumo robot with an ultrasonic eye and two edge sensors.
- Board
- Arduino Uno R3
- Parts
- DRV8833 motor driver, 2WD robot car chassis, HC-SR04 ultrasonic sensor, TCRT5000 line sensor
- Level
- Intermediate
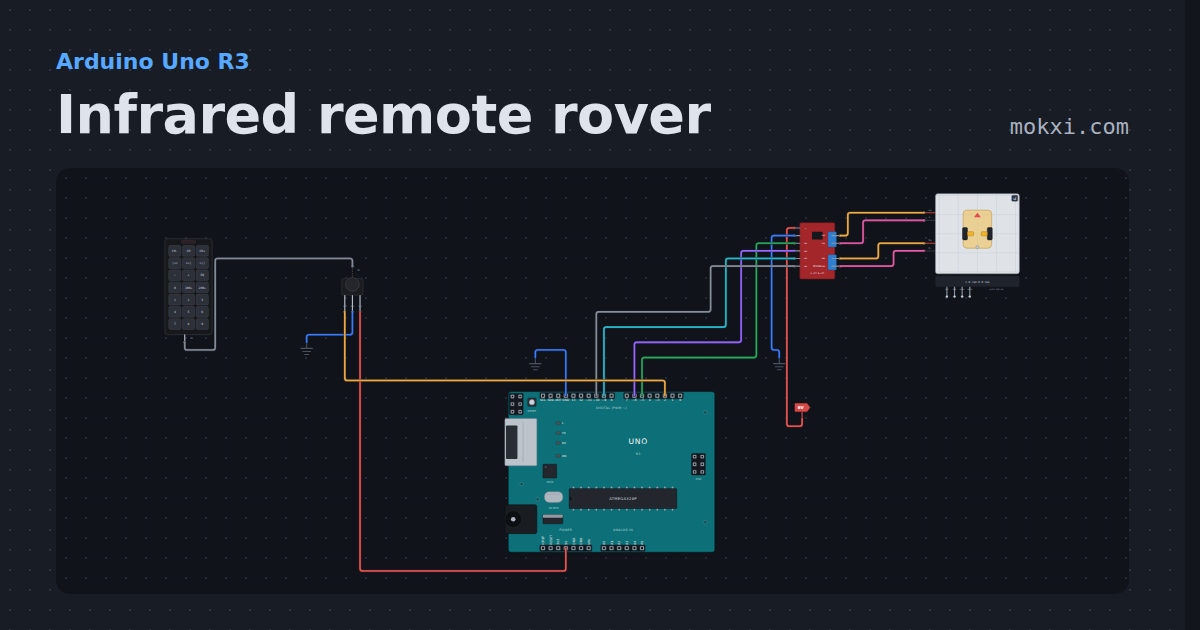
Infrared remote rover
A two-wheel robot driven from a 21-button infrared remote.
- Board
- Arduino Uno R3
- Parts
- MX1508 dual motor driver, 2WD robot car chassis, IR receiver and remote, IR remote
- Level
- Intermediate
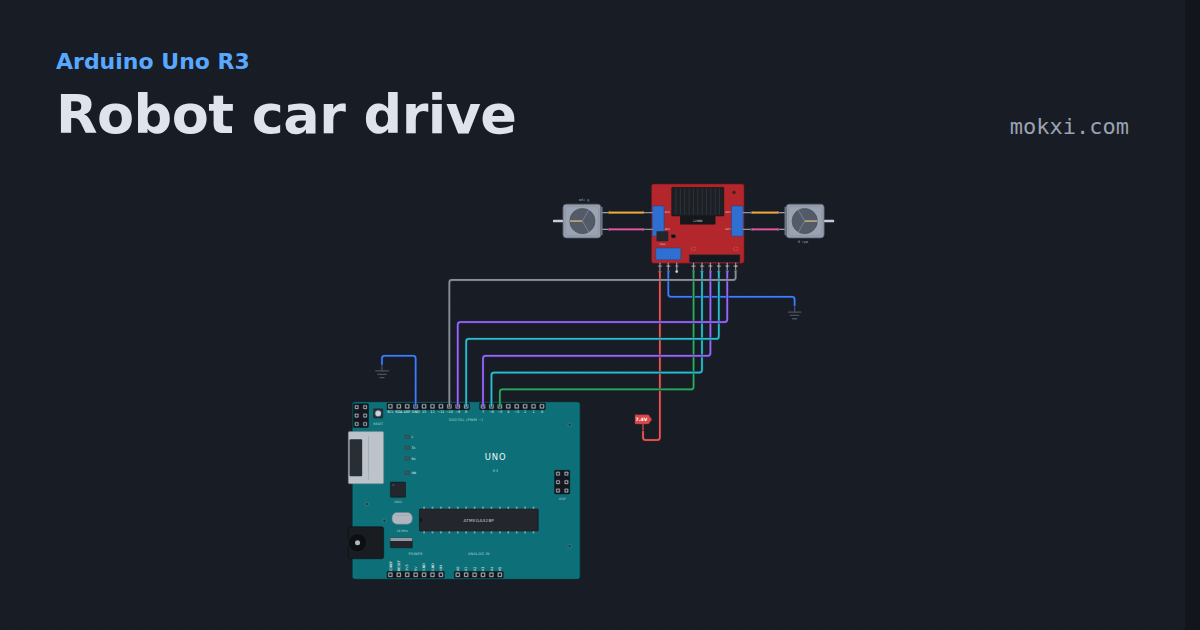
Robot car drive
Two gearbox motors on an L298N module from six Uno pins: forward, a turn, a spin on the spot and reverse, with the speed on ENA and ENB.
- Board
- Arduino Uno R3
- Parts
- L298N motor driver, DC motor
- Level
- Intermediate
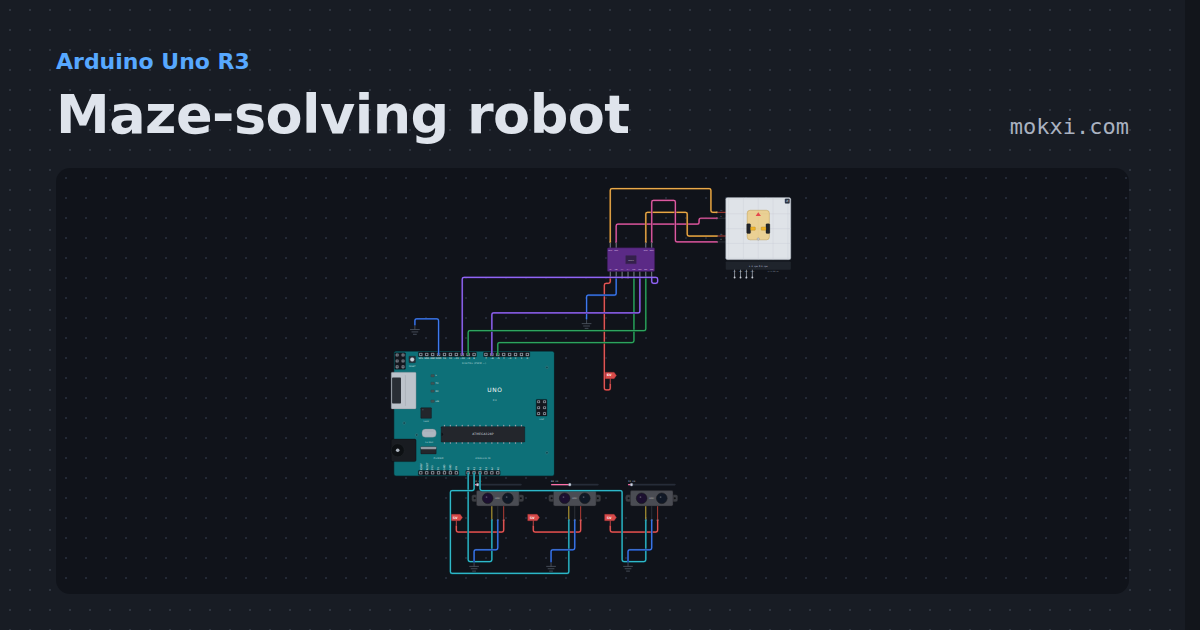
Maze-solving robot
A two-wheel robot with three Sharp infrared distance sensors.
- Board
- Arduino Uno R3
- Parts
- DRV8833 motor driver, 2WD robot car chassis, IR distance sensor
- Level
- Intermediate
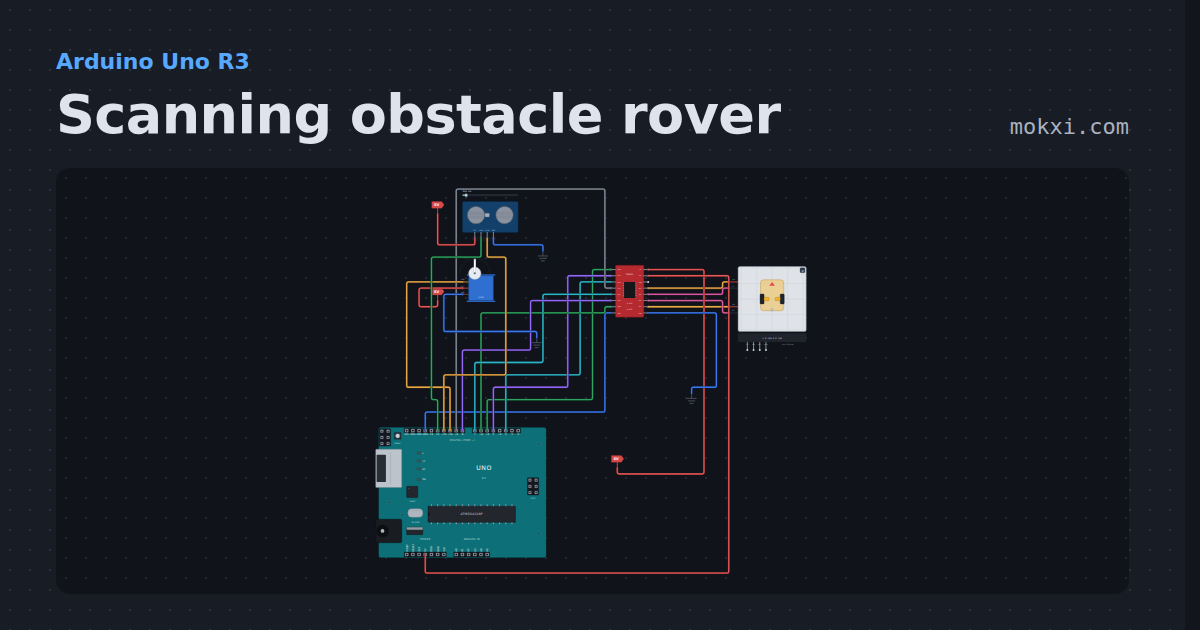
Scanning obstacle rover
A robot with an ultrasonic sensor on a servo neck. Blocked, it stops, looks right, ahead and left, picks the clearest way and turns that way.
- Board
- Arduino Uno R3
- Parts
- TB6612FNG motor driver, 2WD robot car chassis, servo motor, HC-SR04 ultrasonic sensor
- Level
- Intermediate
Factory 3: Robot arm
A servo robot arm picks lumps off one belt and drops them on another. Tune its speed and grab time on two knobs and watch lumps get missed or slip.
- Board
- Arduino Uno R3
- Parts
- ILI9341 TFT display, servo motor, resistor, LED, piezo speaker, +1 more
- Level
- Intermediate
Desk buddy robot
Animated robot eyes on a round GC9A01: it blinks and glances about, beams when you stroke it, gets dizzy when rocked and lonely when ignored.
- Board
- ESP32-C3-DevKitM-1
- Parts
- GC9A01 round display, MPU6050 accelerometer and gyro, touch sensor, photoresistor module, piezo speaker
- Level
- Advanced
Robot arm inverse kinematics
Two knobs set where the claw should be in millimeters, and the Uno solves the shoulder and elbow angles with the law of cosines.
- Board
- Arduino Uno R3
- Parts
- Four-servo robot arm, potentiometer
- Level
- Advanced
Mars rover
A rover that drives three waypoints by dead reckoning, steers around hazards it sees with a sonar mast, samples soil and light.
- Board
- Arduino Uno R3
- Parts
- L298N motor driver, 2WD robot car chassis, push button, SSD1306 OLED display, VL53L0X time-of-flight sensor, +3 more
- Level
- Advanced
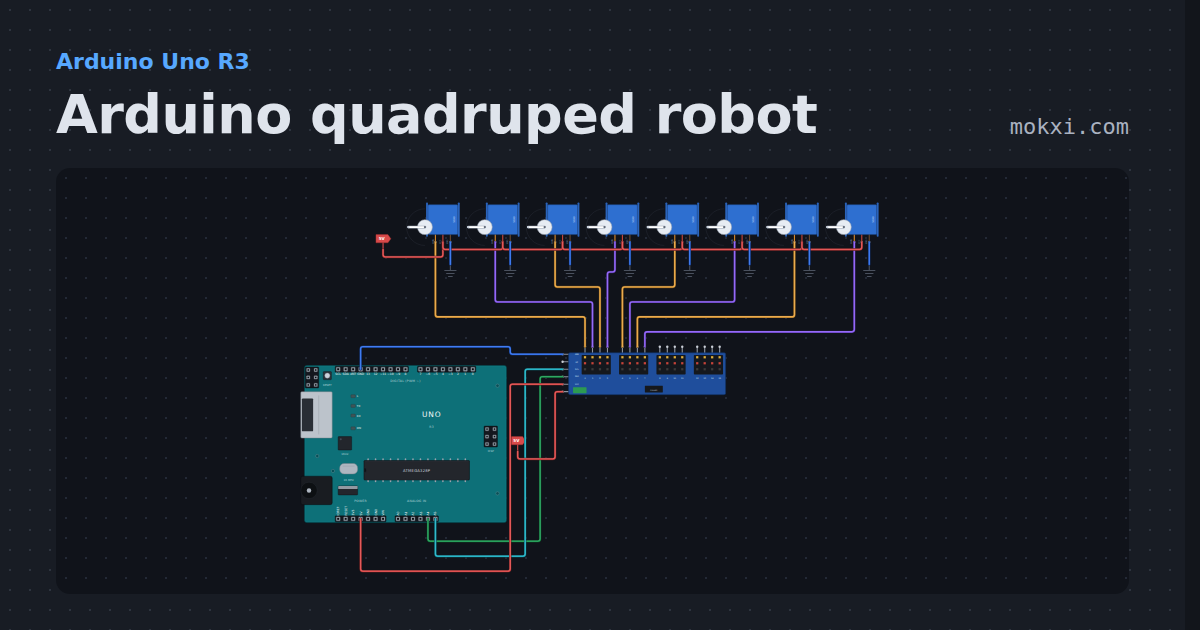
Arduino quadruped robot
Eight servos on a PCA9685 walk a four-legged robot through a creep gait: one foot lifts and swings forward at a time while the other three hold it up.
- Board
- Arduino Uno R3
- Parts
- Servo driver, servo motor
- Level
- Advanced
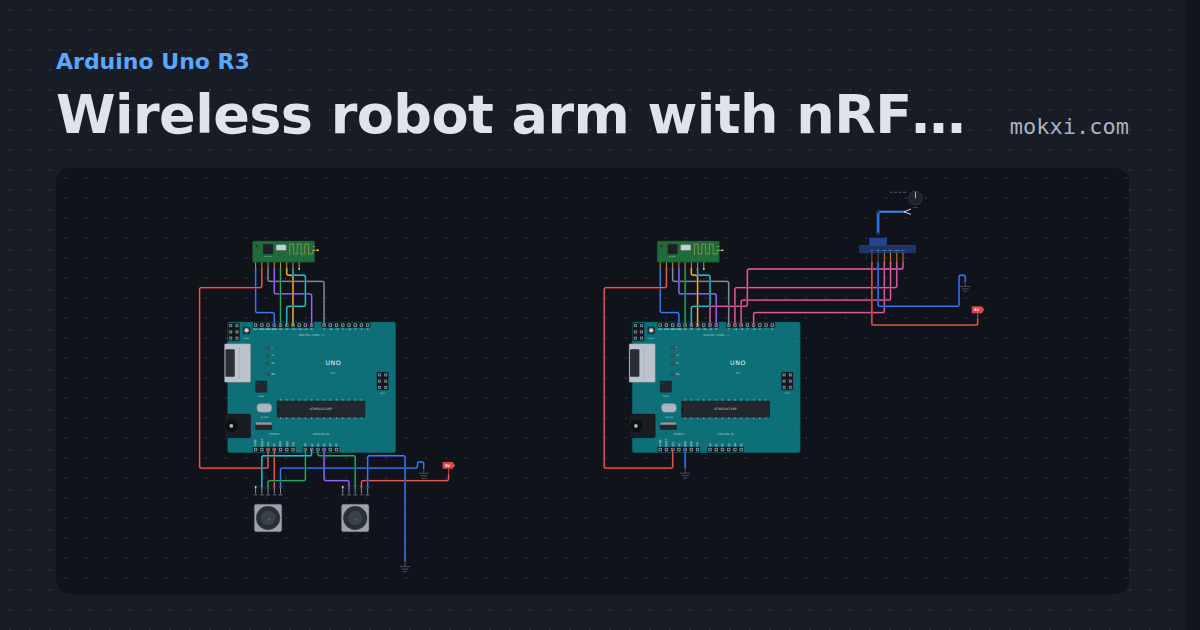
Wireless robot arm with nRF24L01
Two Unos and two nRF24L01 radios: joysticks on one board steer a four-servo arm on the other, with a failsafe that holds the arm when the link drops.
- Board
- Arduino Uno R3
- Parts
- NRF24L01+ 2.4 GHz radio, four-servo robot arm, joystick
- Level
- Advanced
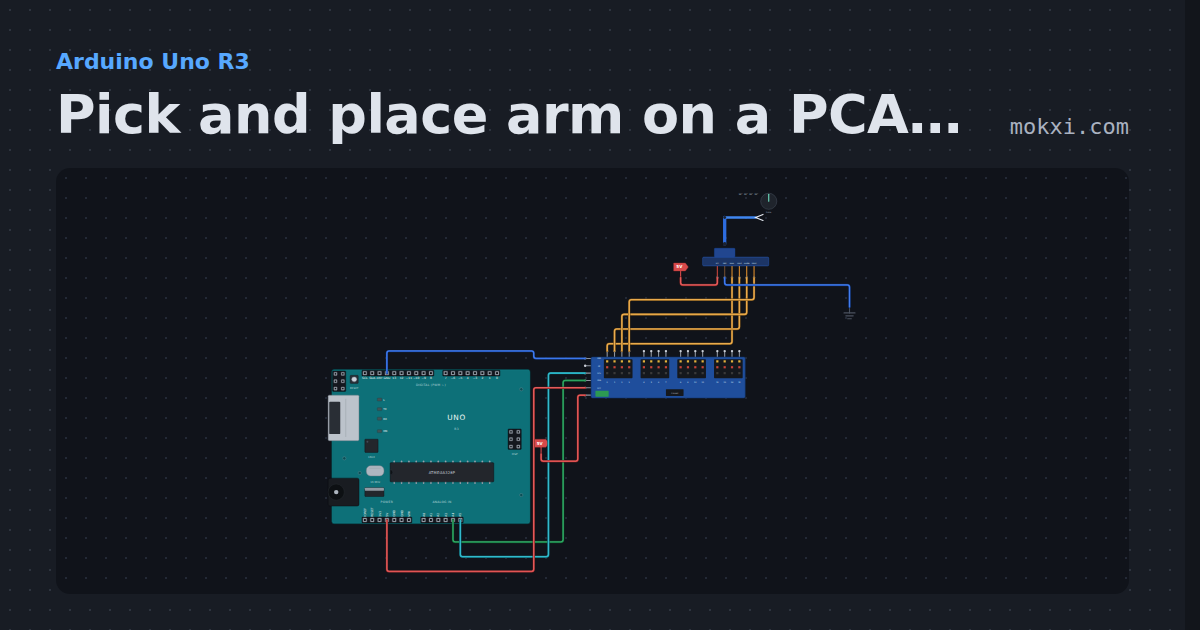
Pick and place arm on a PCA9685
A four-servo arm on a PCA9685 servo board with the Adafruit library: it picks a part up on one side, sets it down on the other and goes home.
- Board
- Arduino Uno R3
- Parts
- Servo driver, four-servo robot arm
- Level
- Advanced
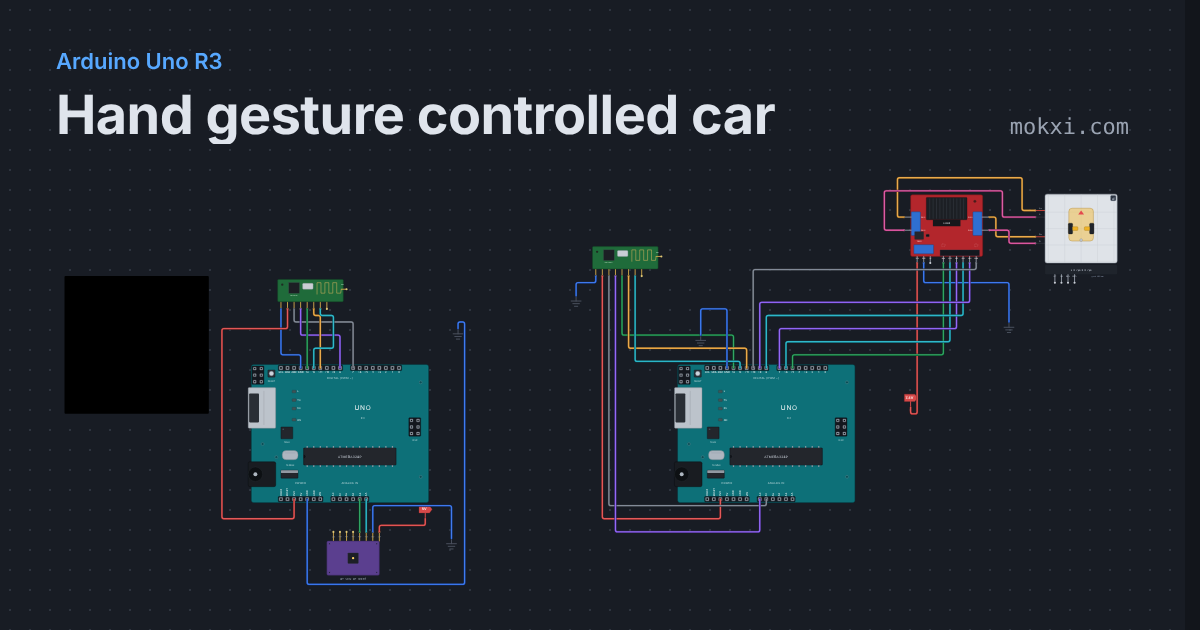
Hand gesture controlled car
Tilt an MPU6050 on your hand and a 2WD car follows over nRF24L01 radios: forward, reverse, left, right, and it stops when the signal is lost.
- Board
- Arduino Uno R3
- Parts
- NRF24L01+ 2.4 GHz radio, MPU6050 accelerometer and gyro, L298N motor driver, 2WD robot car chassis
- Level
- Advanced
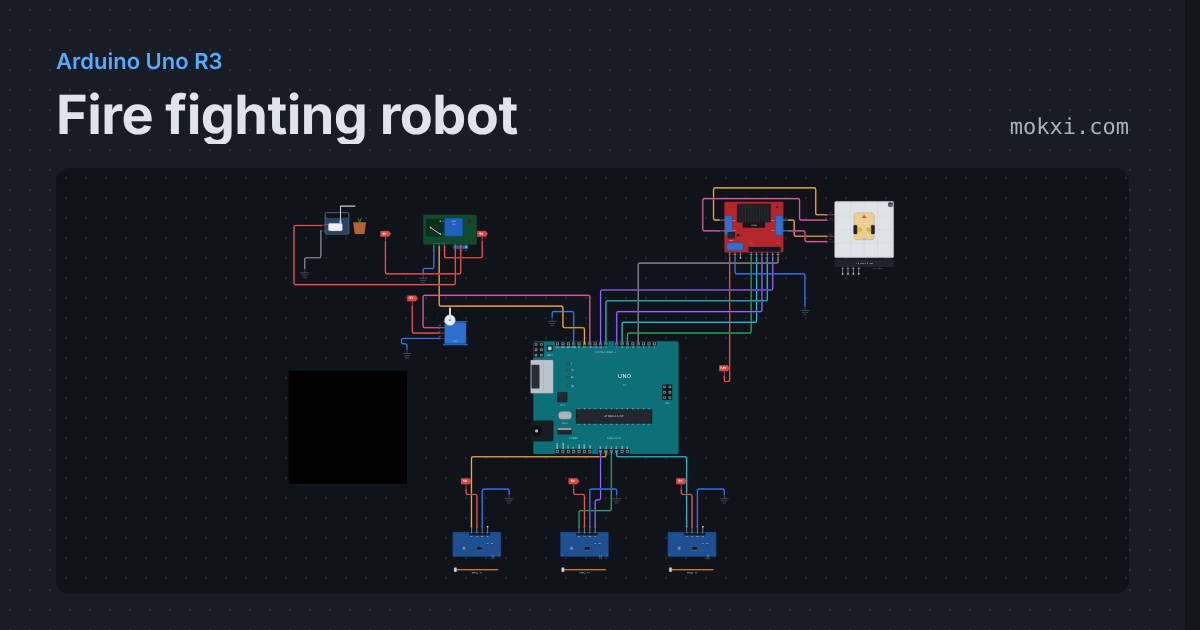
Fire fighting robot
Three flame sensors steer a 2WD car on an L298N to the fire, then a relay runs a water pump while a servo sweeps the nozzle until the flame is out.
- Board
- Arduino Uno R3
- Parts
- L298N motor driver, 2WD robot car chassis, flame sensor, servo motor, relay module, +1 more
- Level
- Advanced
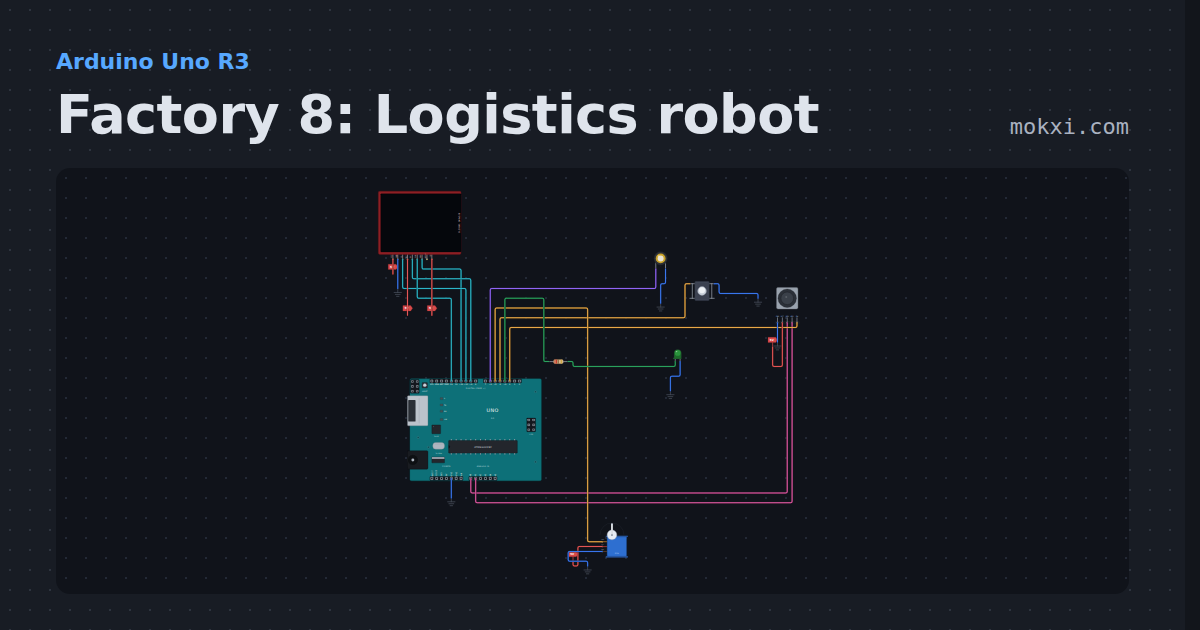
Factory 8: Logistics robot
A delivery robot plans a route around the machines with A* search, fetches crates and brings them to the depot.
- Board
- Arduino Uno R3
- Parts
- ILI9341 TFT display, joystick, push button, servo motor, resistor, +2 more
- Level
- Advanced
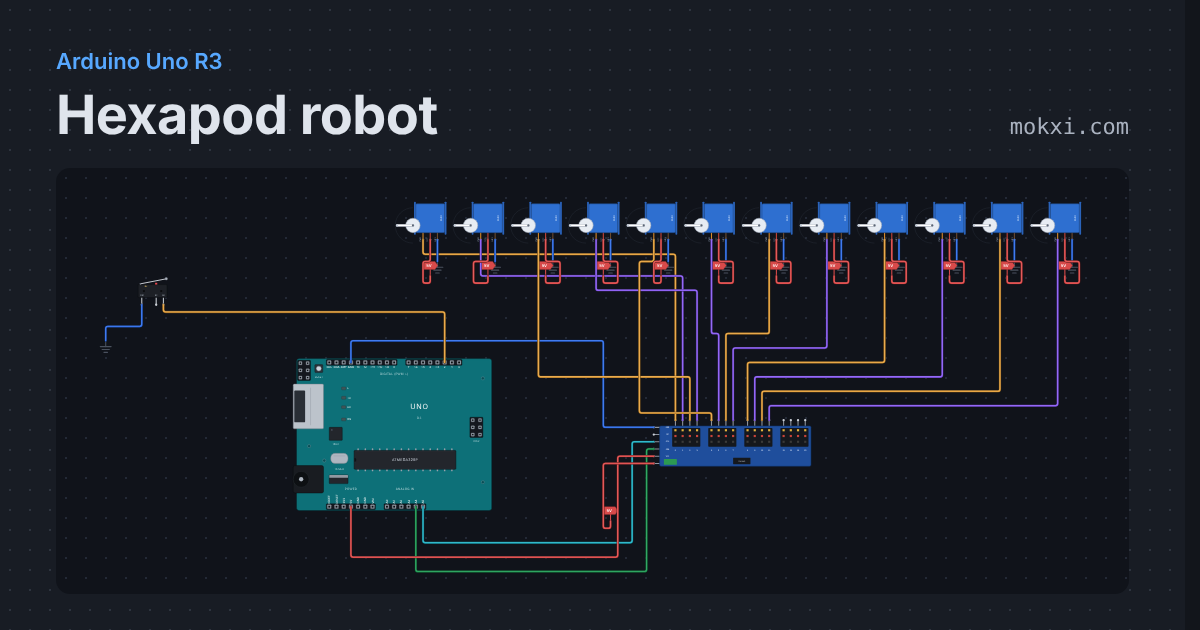
Hexapod robot
Twelve servos on a PCA9685 walk a six-legged robot with the tripod gait: three feet lift and swing forward while the other three hold it up.
- Board
- Arduino Uno R3
- Parts
- Servo driver, limit switch, servo motor
- Level
- Advanced
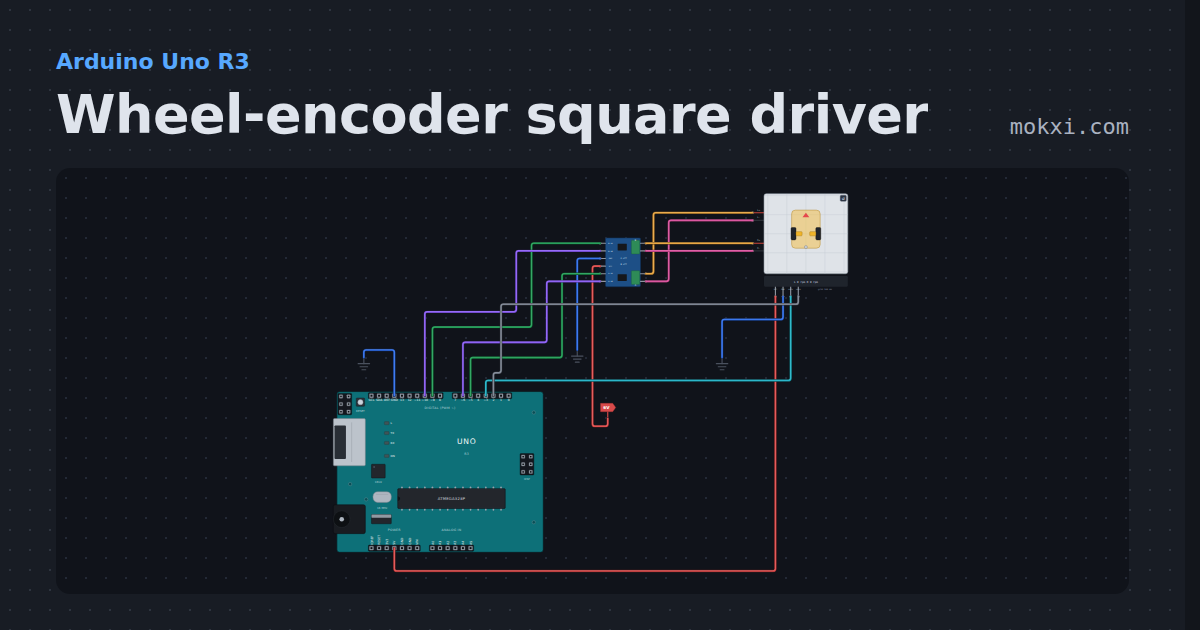
Wheel-encoder square driver
A two-wheel robot that counts pulses from a slot sensor on each wheel.
- Board
- Arduino Uno R3
- Parts
- L9110S motor driver, 2WD robot car chassis
- Level
- Advanced
Wiring, libraries and more ideas
Wiring guides
Library pages
More project ideas
- Arduino Uno project ideas
- Arduino Mega project ideas
- ESP32 project ideas
- Projects with a robot car chassis
- Projects with an L298N motor driver
- Servo motor projects
- Projects with a robot arm
- Projects with a DRV8833 motor driver
- Projects with a joystick
- Projects with an ultrasonic sensor
- Projects with a light sensor module